Delta Intelligence · September 2026
Delta-0 (Δ₀): A New Chapter in Humanoid Intelligence
Core contributor
A humanoid foundation model for whole-body loco-manipulation, coordinating perception, locomotion, and manipulation for everyday tasks.
Second-year PhD student at Shanghai Jiao Tong University, building toward general-purpose humanoids.
I am very fortunate to be co-supervised by Prof. Yong-Lu Li at SJTU, and Dr. Baoxiong Jia and Dr. Siyuan Huang at BIGAI.
Previously, I was a Research Assistant at MARS Lab, Tsinghua University, advised by Prof. Hang Zhao.
I have also interned at NIO, Galaxea Dynamics, and Unitree Robotics.
Delta Intelligence · September 2026
Core contributor
A humanoid foundation model for whole-body loco-manipulation, coordinating perception, locomotion, and manipulation for everyday tasks.
RSS 2026
First author
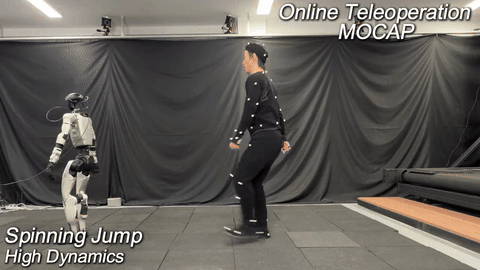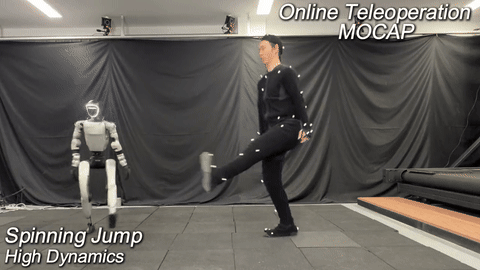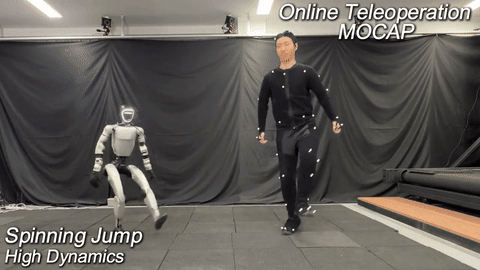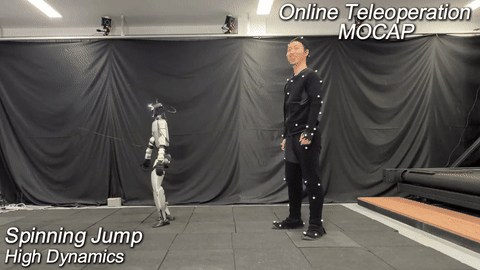
Diverse extreme behaviors in one unified policy.
arXiv 2026
Decoupling physical feasibility from tracking accuracy for stable humanoid motion control.
Introducing Delta-0 (Δ₀), Delta Intelligence’s humanoid foundation model. Explore the demo and blog post.
Presented OmniXtreme at Lumina Talk and RoboPapers.
OmniXtreme accepted at RSS 2026!
Released OmniXtreme and OmniTrack!
"Diffusion-Based Generative Models for 3D Occupancy Prediction" accepted at ICRA 2025.
If you'd like to discuss research or collaboration, feel free to reach out.